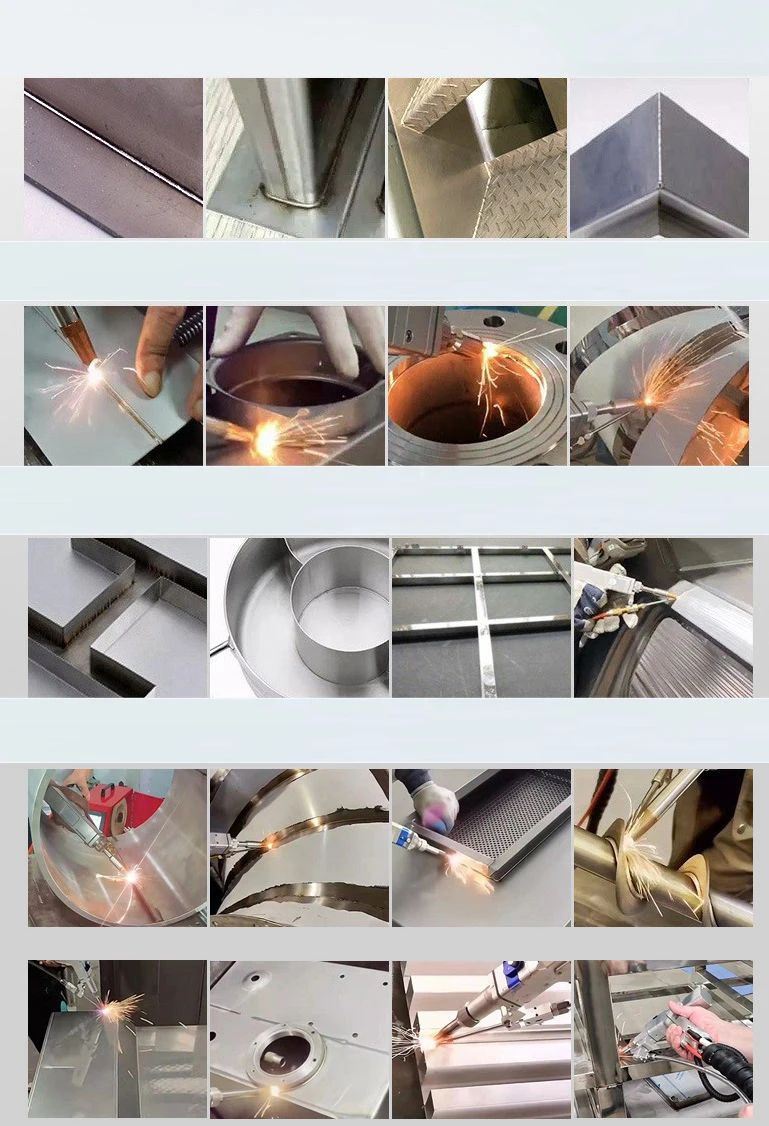
The application of industrial robots in the welding field began with resistance spot welding on automobile assembly lines. The reason is that the process of resistance spot welding is relatively simple, easy to control, and does not require weld trajectory tracking. The control requirements for robot accuracy and repetitive accuracy are relatively low.
Weld tracking technology
In the application process of robots, the application of weld tracking technology is relatively common. When summarizing the welding operation process, due to the fact that the welding process may be affected by factors such as strong arc radiation, soot, spatter, processing errors, fixture accuracy, and workpiece thermal deformation, special attention should be paid to the control of these factors to avoid welding torch deviation from the weld, resulting in problems in welding quality, and the existence of weld tracking technology, To a certain extent, it can monitor the deviation of the weld in real time based on the changes in welding conditions, and timely adjust the welding path and welding parameters, effectively avoiding quality problems during the welding process.
Offline Programming and Path Planning Technology
In the operation process of welding operations, offline programming and path planning technology mainly refers to the further expansion of the robot programming language. It mainly uses the research results of computer graphics to establish a model of the robot's existing working environment, and through professional algorithms to control and operate the graphics of welding devices, which is to enable the robot to conduct welding operations based on the set trajectory planning, Another practical basis for offline programming is the application of automatic programming technology. A technology that assists programmers in programming tasks by applying automatic programming technology to achieve welding tasks, welding parameters, welding paths, and welding trajectories.
Coordinated control technology for multiple robots
In the actual work process, multi-robot coordination control technology mainly refers to an integrated system composed of several robots selected to complete a certain task through cooperation and coordination. In the application process of multi-robot coordination control technology, it is mainly about how to organize equipment to perform effective work according to the actual operation task before the multi-system arranges a certain task. After determining the working mechanism, it is necessary to consider how to maintain the consistency of robot motion coordination in combination with actual work.
Special arc welding power source
Continuous practical work experience has shown that in the system, a dedicated arc welding power source with good electrical performance is one of the keys to ensuring the normal performance of the equipment. Most of the special arc welding inverters used by robots are transistor type arc welding inverters controlled by a single chip microcomputer. The precise waveform control method of the welding power supply can ensure the consistency of the welding width and depth to a certain extent, promoting a more beautiful welding surface. Therefore, in the application process, it is very important to conduct in-depth research on special arc welding power sources.